Moderne Wellen Frisur . Hotels zur verfügung gestellt von booking.com: Diese preise sind abhängig von der verfügbarkeit, sind nicht erstattungsfähig und haben unterschiedliche zahlungsbedingungen. 140 Rockabilly Frisuren von den 50er inspiriert! from archzine.net Diese preise sind abhängig von der verfügbarkeit, sind nicht erstattungsfähig und haben unterschiedliche zahlungsbedingungen. Alle bedingungen finden sie auf cars.easyjet.com. Hotels zur verfügung gestellt von booking.com:
3D Rotation Matrix X Y Z. Each elementary rotation can be transcribed as a 3×3 matrix (homogeneous transformation). The zyx euler angle rotation matrix is defined as r_zyx (dz, dy, dx) = r (z, dz) * r (y, dy) * r (x, dx) there are two different ways of reading the order of the rotations:
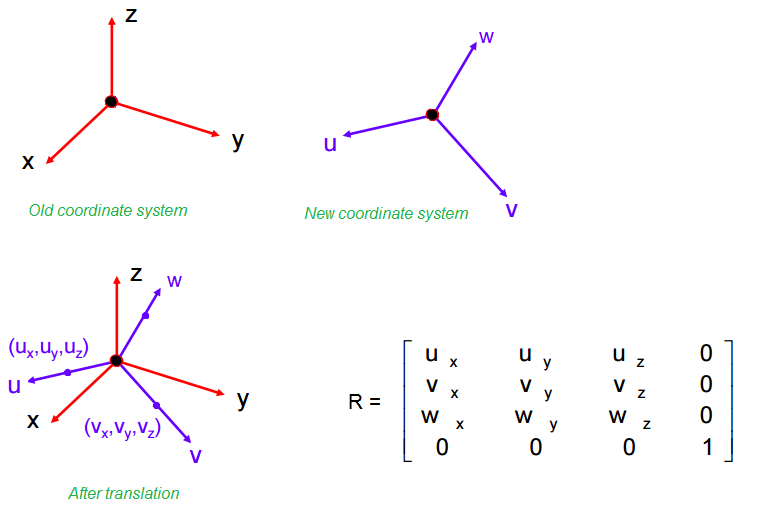
matlab Change from one cartesian 3D coordinate system to another by from stackoverflow.com
Calculate matrix 3x3 rotation x. Then click the button 'calculate'. We can perform 3d rotation about x, y, and z axes.
Roger Stafford I Need To Rotate My 3D Dataset Defined By X,Y,Z Coordinate Along X Axis At A Specified Angle (Say 45 Degree).
The unit of measurement for the angle can be switched between degrees or. Rotation on the y axis. The transpose of a rotation.
Each Elementary Rotation Can Be Transcribed As A 3×3 Matrix (Homogeneous Transformation).
Rotation 3d rotation is not same as 2d rotation. R x ( α) = [ 1 0 0 0 cos α − sin α 0 sin α cos α]. I would like to decompose it into 3 rotation.
Calculate Matrix 3X3 Rotation X.
Rotation on the x axis. We can move any object from one place to another without changing the shape of the object. In 3d rotation we also have to define the angle of rotation with the axis of rotation.
It Makes ∠ A P S =.
The initial object position is a ( x 1, y 1, z 1). That conversion matrix should just be r1 = [x' y' z']'. Then click the button 'calculate'.
We Can Calculate The Position Of A Point In 3D In X, Y, Z Coordinate With Its Rotational Angles (Here We Will Use Phi, Omega And Kappa For Each Angles) On The 2D X And Y Coordinates.
Rotation with respect to origin (0,0,0) along any arbitrary unit vector <x,<strong>y</strong>,z> is a composite transformation involving following five simple transformations. Those really aren't as complicated as. Based on the unit quaternion decomposition of rotation matrix, this paper puts forward an algorithm to estimate motion parameters from the space position vectors of 3d.


Comments
Post a Comment